Soft hands
Soft where it touches. Rigid where it counts.
A gripper that changes stiffness on demand.
From the research
One hand. Every kind of grip.
70×stiffness range, soft to rigid
0.2 sto switch from rigid to soft
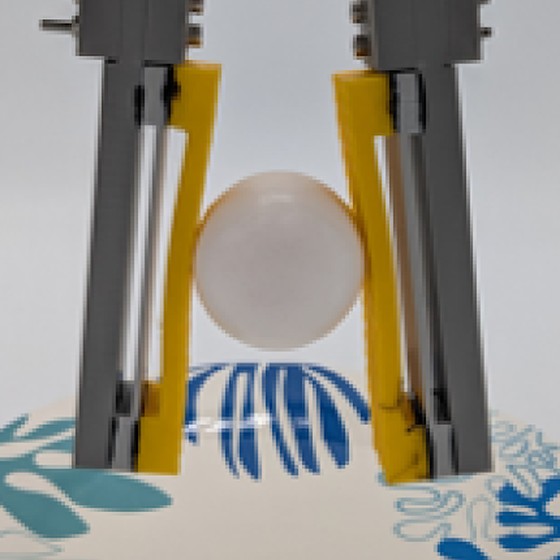
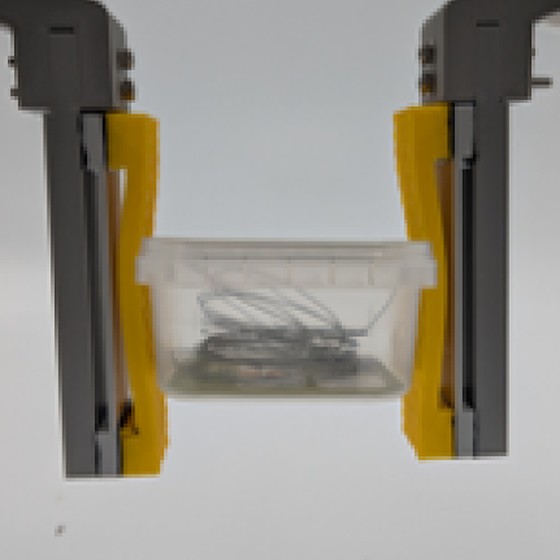
30+objects grasped, eggshell to metal block
Sources: Robotica (2023); Journal of Mechanisms and Robotics (2024). Patent pending.
Lab tests
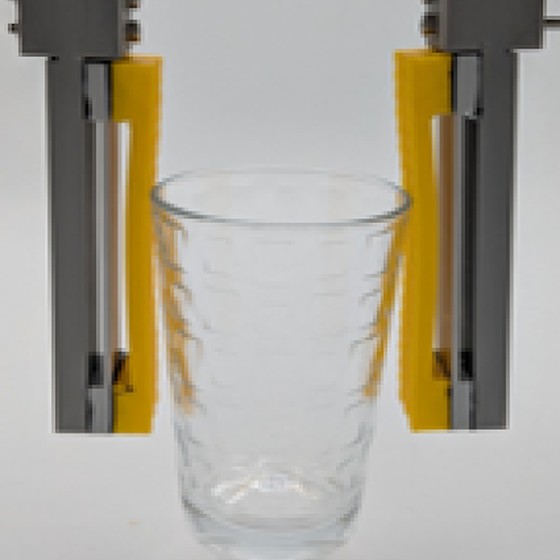
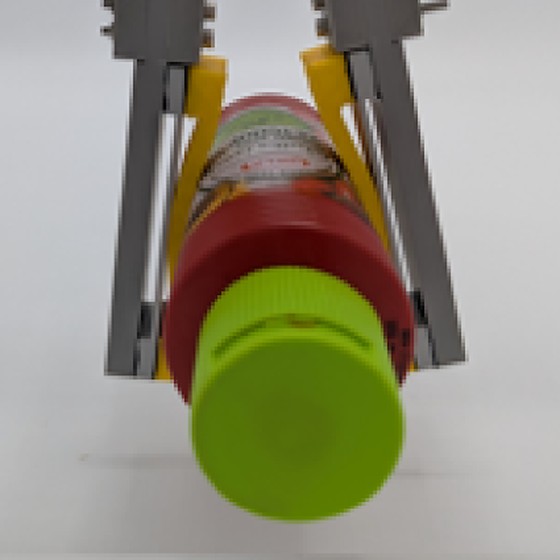
Glass, bottles, balls, boxes.
Inside
Three layers and a sense of touch.
- Soft skinConforms to the object
- Variable layerSets the stiffness
- Rigid coreCarries the load
See it live
Hold one yourself.
Tell us about your work. We’ll show you the rest in person.